Sprint Biomechanics & Technique: The Complete Technical Reference
Acceleration phase, maximum velocity, deceleration — the mechanics of sprinting and what heavy lifters need to work on.
By Dhiren Dunraj MSc
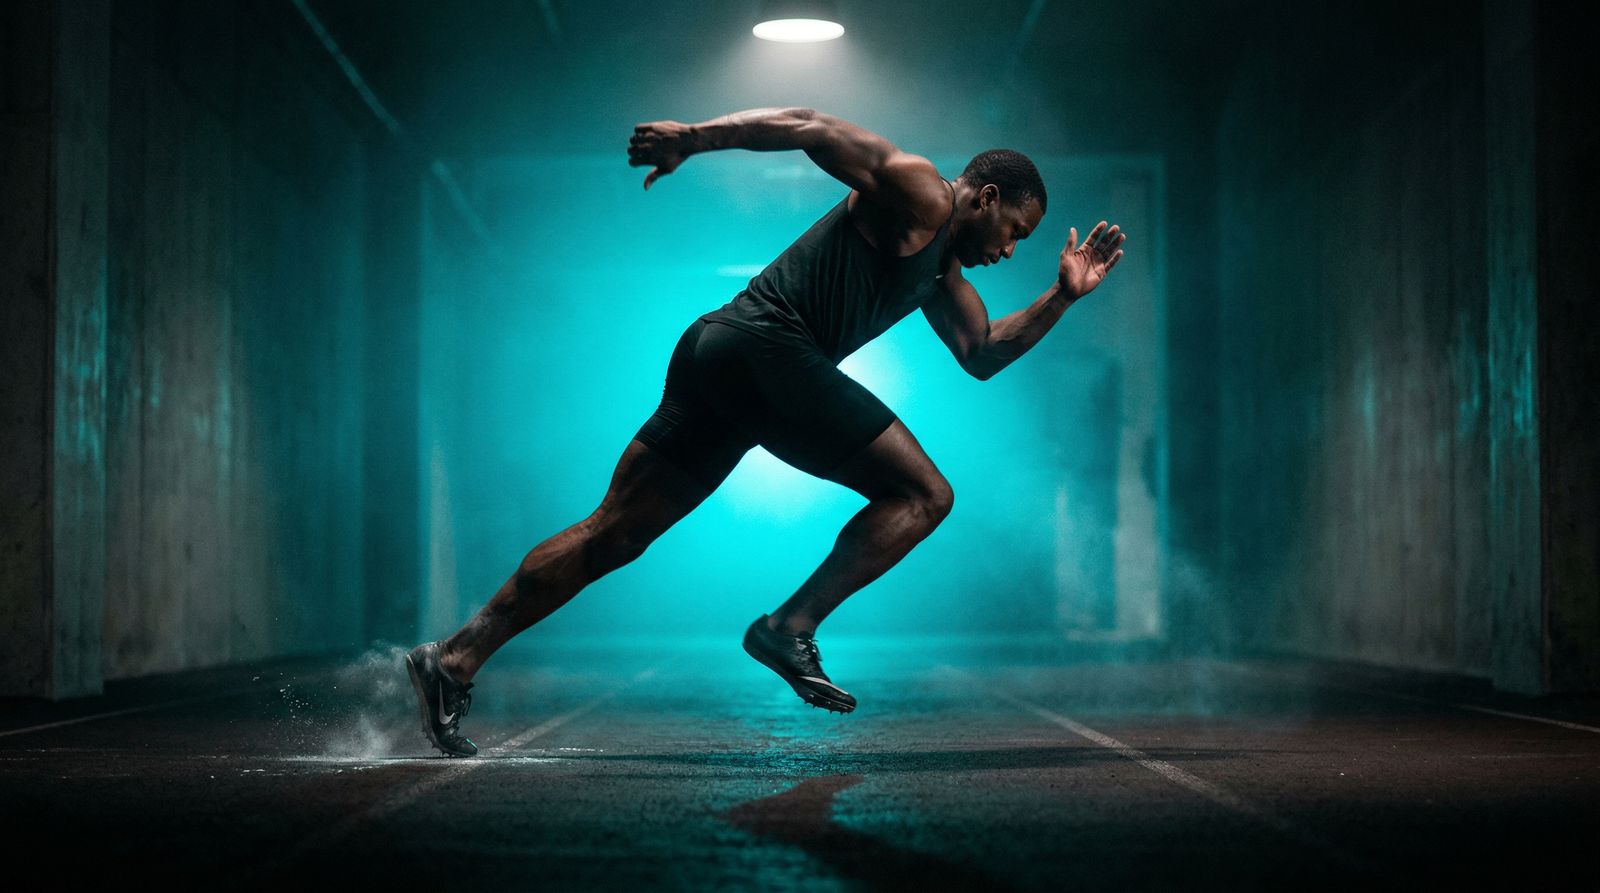
Key Insight
“The strongest athletes in the gym are not automatically the fastest on the track. They can be, once they understand why their strength isn't transferring.”
Heavy lifters have one of the most transferable strength profiles for sprint acceleration that exists in sport. Massive hip extension output. Dense posterior chain musculature. The ability to apply enormous force into the ground. By the physics of sprinting, you should be fast.
Many aren't. The deficits are specific and fixable once you understand the mechanics. This is the complete technical reference.
Why Sprinting Technique Matters for Heavy Lifters
Sprint speed is the product of force application, mechanics, and neurological timing working simultaneously. A strength athlete stepping onto a track for the first time brings enormous contractile capacity but often lacks the mechanical pattern to express it as velocity.
Strength is only useful if it goes through the right movement pattern, at the right time, in the right direction. A 300kg squat produces no sprint speed if the foot is landing in front of the centre of mass, the hip is sitting rather than driving, or the ankle lacks the stiffness to transmit ground force efficiently.
Three structural deficits are common across heavy lifters who sprint:
Dorsiflexion restriction. Years of squat training, particularly with a heeled shoe, and the sustained ankle load of heavy belt work can progressively limit ankle dorsiflexion range. This directly impairs maximum velocity mechanics. Without sufficient dorsiflexion through the swing phase, the foot cannot achieve the correct contact position and elite sprinting economy becomes impossible.
Hip flexor range. Heavy loaded hip extension work (squats, deadlifts, hip thrusters) shortens the hip flexors through repeated concentric loading and chronic positioning in extension. Reduced hip flexor range directly caps knee drive height at maximum velocity, which is the primary determinant of stride length at speed.
Stride frequency. This quality is not trainable in the weight room. Ground contact time reduction, the neurological coordination of rapid limb cycling, and the elastic energy return from tendons under velocity load all require a sprint-specific stimulus. Strength is necessary but not sufficient.
Sprint technique is a trainable skill. The mechanics below determine whether your strength transfers to speed, or stays trapped in the gym.
Acceleration Phase (0–30m)
The acceleration phase is the strength athlete's strongest terrain. Hip extension, the dominant quality of the squat and deadlift, is the primary driver of acceleration. The physics are direct: ground reaction force applied behind the centre of mass equals forward propulsion.
Body Position
Forward lean originates from the ankles, not the hips. At the start, lean approaches 45 degrees from vertical, a straight line from heel to crown of head. As speed builds, the torso progressively rises. An athlete sitting into the hips (torso upright, hips flexed, knees bent) loses propulsive angle entirely. The force vector goes downward, not backward. This is the most common fault in novice sprinters: confusing the feeling of effort with the correct mechanics of lean.
The spine is neutral throughout. No chin jutting forward, no excessive lumbar extension. The head leads the direction you want to go.
Triple Extension
Each ground contact in the acceleration phase should produce simultaneous hip extension, knee extension, and plantarflexion. This is triple extension — the same movement pattern as the clean pull, the box jump, the sled push. The heavy lifter's strength in this pattern feeds directly into sprint propulsion.
The foot should push backward through ground contact, not downward. The distinction matters. Pushing downward produces vertical force. Pushing backward produces horizontal propulsion. Coaching cue: think of scraping mud off the bottom of your shoe.
Arm Drive
Arms operate as pistons, not pendulums. The elbow holds at approximately 90 degrees throughout. The movement is almost entirely backward: a powerful drive of the elbow behind the body. The forward swing is a recovery, not a drive. Fists are relaxed (tight fists recruit tension through the shoulder and neck, killing mechanics above the waist). Arms do not cross the midline. Crossing the midline rotates the trunk, disrupts the linear force vector, and kills efficiency.
Ground Contact
Contact time during acceleration targets 0.12–0.18 seconds per step. This is longer than maximum velocity. The athlete is loading the ground, applying force, producing propulsion. Stride length increases progressively during acceleration. Frequency builds. Neither is forced: both are outputs of correct mechanics applied at increasing speed.
Common Acceleration Faults
Sitting into the acceleration. Torso upright, hips behind the feet. Cause: quad dominance, failure to push through hip extension. Fix: sled push drills at heavy load, A-march drills with exaggerated forward lean.
Overstriding. Foot contacts the ground ahead of the centre of mass. This creates a braking force, the opposite of propulsion, on every single step. Cause: attempting to run faster by reaching further. Fix: wall drill (lean against wall at correct angle, drive knee up, contact drill), A-skip.
Arm crossing midline. Each arm swing rotates across the centreline of the body. Cause: lat tension, shoulder tightness, lack of isolated arm drive pattern. Fix: seated arm drive drills, arm swing isolation with resistance band.
Maximum Velocity Phase (30–60m)
By 30–40 metres for most trained athletes, the acceleration phase is complete. Top speed is reached and the mechanical demands shift entirely. This phase exposes the structural deficits of heavy lifters most clearly.
Posture
The body transitions to near-upright. A slight forward lean remains. Removing it entirely shifts the force vector backward and causes deceleration. The hips are high, the pelvis in neutral. Any posterior tilt (tucking under) shortens stride length.
Knee Drive
The thigh must reach parallel or above during the swing phase. This is where hip flexor range becomes the rate-limiting factor for many strength athletes. Insufficient hip flexor range means the knee drive is cut short, stride length is reduced, and velocity is capped below its potential. The fix is hip flexor mobility work as a consistent priority rather than an occasional warm-up afterthought, not more sprint volume.
The Pawing Action
At maximum velocity, the foot sweeps backward into contact in what coaches call the "pawing" action. The foot contacts the ground directly beneath or marginally behind the centre of mass, moving backward relative to the body. This minimises braking forces and maximises propulsive output.
Ground contact time at maximum velocity drops to 0.08–0.10 seconds for elite sprinters. It comes from correct mechanics, not from trying to shorten contact time: high knee drive, correct contact position, sufficient ankle stiffness. The contact time is an output, not a target you consciously pursue.
Ankle Stiffness and Dorsiflexion
Maximum velocity sprinting relies on the elastic properties of the Achilles tendon and calf musculature. The ankle must be stiff at ground contact. This stiffness allows the tendon to store and return elastic energy rather than dissipating it as deformation. A soft, collapsing ankle at ground contact is an energy sink.
The foot must achieve dorsiflexion through the swing phase to arrive at ground contact in the correct position. A heavy lifter with restricted dorsiflexion will heel-strike at maximum velocity: the foot arrives plantar-flexed (toe-down), contacts with the heel first, and creates a braking impulse on every step. This is a range of motion problem, not a strength problem, and it must be addressed with targeted ankle mobility work (banded dorsiflexion stretches, elevated heel stretches, pogo jumps for stiffness development) before sprint volume can be effective.
Relaxation Under Speed
The paradox of maximum velocity: maximal effort requires maximal relaxation above the hips. The hip flexors and extensors are working at their highest output. Everything above the hip (the shoulders, the jaw, the hands, the face) must be relaxed. Tension in the upper body shortens stride length, disrupts arm mechanics, and costs speed.
This is genuinely difficult for heavy lifters. You have trained for years to brace under maximal load. The motor pattern of total body tension is deeply ingrained. Maximum velocity sprinting requires the opposite: selective relaxation while maintaining lower body power. Jaw relaxation is an effective cue. A loose jaw is incompatible with upper body tension.
Deceleration Phase (60m+)
Deceleration begins naturally after 60–80 metres for most athletes, earlier for those less sprint-trained. The mechanics of controlled deceleration are as important as the mechanics of acceleration. An athlete who decelerates poorly risks hamstring injury.
The braking stride. As fatigue sets in, the instinct is to reach forward to maintain stride length. This produces anterior ground contact (the foot lands ahead of the centre of mass), which creates braking forces and places severe eccentric load on the hamstring at a moment when the muscle is already fatigued. This is the primary mechanism of hamstring strain in sprinting.
Controlled deceleration. Allow stride frequency to reduce naturally. Maintain posture. Do not let the torso collapse forward or the head drop. Allow speed to reduce over 20–30 metres minimum after a true maximal sprint. Never sprint at full effort and then stop abruptly. This is both ineffective at protecting the hamstring and counterproductive to the elastic energy system you are trying to develop.
Common Sprint Faults and Corrections
| Fault | Phase | Cause | Fix |
|---|---|---|---|
| Hip sitting (torso upright, hips behind feet) | Acceleration | Quad dominance, not driving through hip extension | Sled push drills, A-march drills |
| Overstriding | Acceleration and MaxV | Attempting to run faster by reaching forward | Wall drill, lean drill, A-skip |
| Arm crossing midline | All phases | Lat tension, shoulder tightness | Arm drive isolation, seated arm swings |
| Heel striking at maximum velocity | MaxV | Limited dorsiflexion, poor ankle stiffness | Ankle mobility work, pogo jumps |
| Head bobbing | MaxV | Upper body tension, loss of posture | Jaw relaxation cue, neutral chin |
| Immediate stop after sprint | Deceleration | Deceleration not practised as a skill | Planned 20–30m deceleration zones |
The Heavy Lifter's Sprint Profile
Advantages
Hip extension power. The most important quality in sprint acceleration is the ability to apply high ground reaction force in the horizontal direction during the push-off phase. The squat and deadlift are, mechanically, hip extension training at high load. This transfers directly.
Posterior chain mass. The glutes, hamstrings, and calves provide the contractile tissue for ground force application. A strength athlete carries more of this tissue than almost any other athlete category.
Rate of force development. Years of maximal lifting, particularly with explosive intent, develops the ability to apply force quickly, a quality that underpins ground contact efficiency.
Deficits
Dorsiflexion. Years of squatting in heeled shoes, loaded ankle positioning, and the tissue changes that accompany heavy lower body training frequently produce restricted dorsiflexion. This is the single most common sprint-specific deficit in heavy lifters. Address it before adding sprint volume.
Hip flexor range. The heavy loaded hip extension required by competition lifting shortens hip flexors through chronic positioning and repeated concentric contraction. This needs consistent loaded and unloaded range of motion work, not occasional hip flexor stretching.
Stride frequency. Not a weight room quality. Requires a sprint-specific stimulus. Start with lower volumes at submaximal intensity and allow the neuromuscular system to adapt to the movement pattern before pursuing maximum velocity work.
Relaxation. The motor pattern of maximal effort brace is deeply embedded. Learning to apply lower body power while relaxing above the hips is a skill that requires deliberate, repeated practice.
Sprint-Specific Warm-Up Protocol
A sprint warm-up is not optional. Maximum velocity sprinting on a cold body is the most efficient route to a hamstring tear.
General mobilisation (5 minutes) Ankle circles (10 each direction per ankle), hip circles (10 each direction), leg swings sagittal plane (15 per leg), leg swings frontal plane (10 per leg), thoracic rotation in half-kneeling (8 per side).
Activation drills (5 minutes) Glute bridges (15 reps, slow), banded hip abduction (15 per side), standing calf raises (20 reps, slow through full range), hip flexor mobilisation in half-kneeling with posterior pelvic tilt (8 per side, hold 3 seconds at end range).
Mechanical drills (5–7 minutes) A-march: exaggerated march with high knee drive, arm drive practice, and deliberate dorsiflexion, 2×20m. A-skip: rhythmic bounding skip with knee drive emphasis, 2×20m. B-skip: A-skip with an added knee extension and pawing action, coordinating the full stride cycle, 2×20m. Straight-leg bounding: stiff ankle contacts with active hamstring sweep, 2×20m.
Progressive build-ups 3 runs at progressively increasing intensity: 60m at 50% effort, 60m at 70% effort, 60m at 85% effort. Do not go to true maximum velocity cold. The build-ups prime mechanics and prepare the elastic structures for full sprint demand.
Heavy Lifter Sprint Prescription
Scheduling. Do not sprint on squat or deadlift days. The neuromuscular and structural fatigue from heavy lower body loading compromises sprint mechanics and elevates injury risk substantially. Ideal placement: a dedicated conditioning session, or on an upper body training day.
Acceleration work (0–30m) Full warm-up. 6–10 repetitions of 20–30m sprints. Full recovery between reps: walk back, minimum 2–3 minutes. Fatigue accumulation destroys mechanics and turns sprint training into extended conditioning, which is a different stimulus with different adaptations. For sprint development, quality of mechanical execution takes precedence over volume.
Maximum velocity work Flying 10–20m: build through 30m, then sprint maximally through a 10–20m zone. This removes the acceleration phase stimulus and isolates the maximum velocity demand. 4–6 repetitions, full recovery (4–5 minutes minimum per rep). This is advanced. Establish clean acceleration mechanics before pursuing maximum velocity work.
Key Takeaways
- Heavy lifters have elite-level hip extension strength that transfers directly to sprint acceleration. The limiting factor is mechanics, not capacity
- Dorsiflexion restriction and limited hip flexor range are the two structural deficits that most commonly prevent strength from transferring to sprint speed
- Acceleration phase: forward lean from the ankles, triple extension, foot pushes backward not downward, arm drive is a backward piston action
- Maximum velocity: high knee drive to parallel or above, pawing foot contact beneath the centre of mass, upper body relaxation is a mechanical requirement not a preference
- Deceleration is a skill. Practise it deliberately to protect the hamstring under fatigue
- Sprint volume without clean mechanics produces injury, not speed
Put It Into Practice
This week: Do the sprint warm-up protocol before any lower body session. Identify your dorsiflexion restriction. The ankle mobility work should start immediately, regardless of whether you are sprinting yet.
This training block: Add one acceleration session per week on a non-squat/deadlift day. Start with 6×20m at 85% effort. Use the drill sequence. Build the mechanical pattern before adding distance or intensity.
Long term: Develop clean acceleration mechanics over 6–8 weeks before moving to any maximum velocity work. Address hip flexor range and dorsiflexion as ongoing priorities: dedicated mobility practice that happens year-round, not pre-sprint warm-up items.
Analysed by FINAL FORM AI. Your form, perfected.
References
- 1Mero, A., Komi, P. V., & Gregor, R. J. (1992). Biomechanics of sprint running. Sports Medicine, 13(6), 376–392. PMID: 1615256
- 2Weyand, P. G., Sternlight, D. B., Bellizzi, M. J., & Wright, S. (2000). Faster top running speeds are achieved with greater ground forces not more rapid leg movements. Journal of Applied Physiology, 89(5), 1991–1999. PMID: 11053354
- 3Mann, R. (2013). The Mechanics of Sprinting and Hurdling. CreateSpace.
- 4Lockie, R. G., Murphy, A. J., & Spinks, C. D. (2003). Effects of resisted sled towing on sprint kinematics in field-sport athletes. Journal of Strength and Conditioning Research, 17(4), 760–767. PMID: 14636109
- 5Morin, J. B., Bourdin, M., Edouard, P., et al. (2012). Mechanical determinants of 100-m sprint running performance. European Journal of Applied Physiology, 112(11), 3921–3930. PMID: 22422028
- 6Clark, K. P., & Weyand, P. G. (2014). Are running speeds maximized with simple-spring stance mechanics? Journal of Applied Physiology, 117(6), 604–615. PMID: 25080925
- 7Haugen, T., Seiler, S., Sandbakk, Ø., & Tønnessen, E. (2019). The training and development of elite sprint performance: an integration of scientific and best practice literature. Sports Medicine - Open, 5, 44. PMID: 31754845